A Unified Continuum Robot Actuation Platform

Open-source hardware and software to help researchers get started with high-DOF robots. We focus on continuum robots, but the platform is agnostic to robot type!

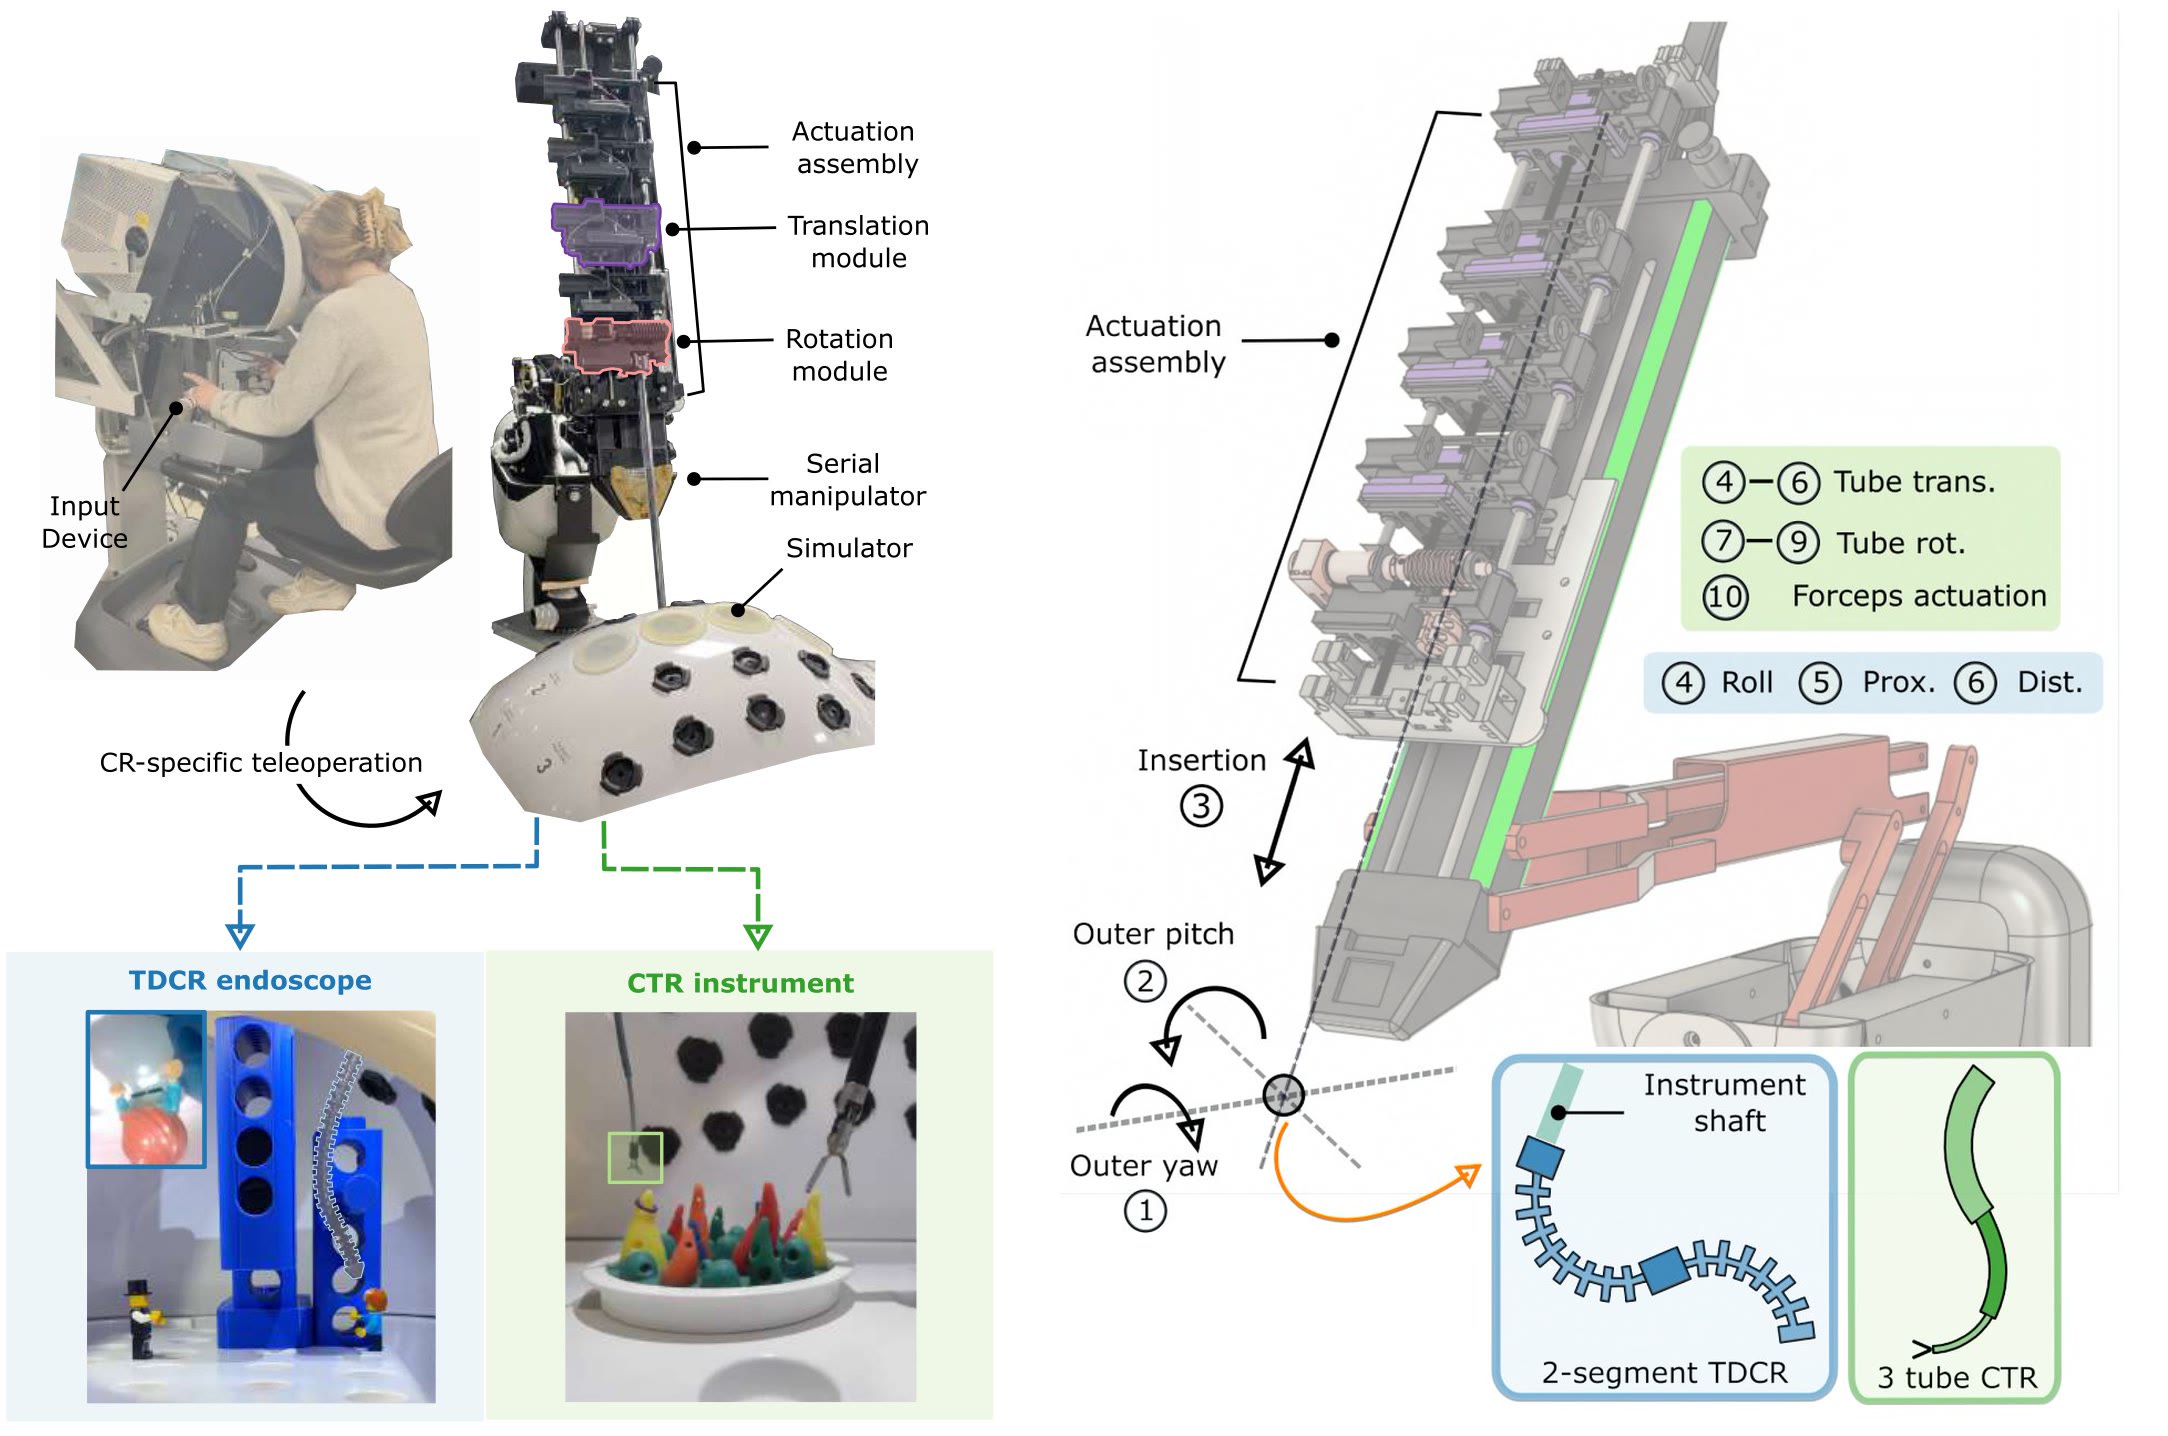
Left: system overview, an operator at the input device teleoperates the actuation assembly on a serial manipulator over a surgical simulator, driving a TDCR endoscope and a CTR instrument. Right: degrees of freedom, outer yaw, outer pitch and insertion plus actuation-assembly DOFs for a 2-segment TDCR or a 3-tube CTR

Sub-millimeter translational accuracy and less than 5° rotational error, over ranges of 30 mm and 180°, respectively.

Team
Early Adopters
UC San Diego
Stanford
Vanderbilt
UC Santa Barbara
UNC
Driving a tendon-driven continuum robot (TDCR) on a dVRK
Driving a concentric tube robot (CTR) on a dVRK

Design Overview

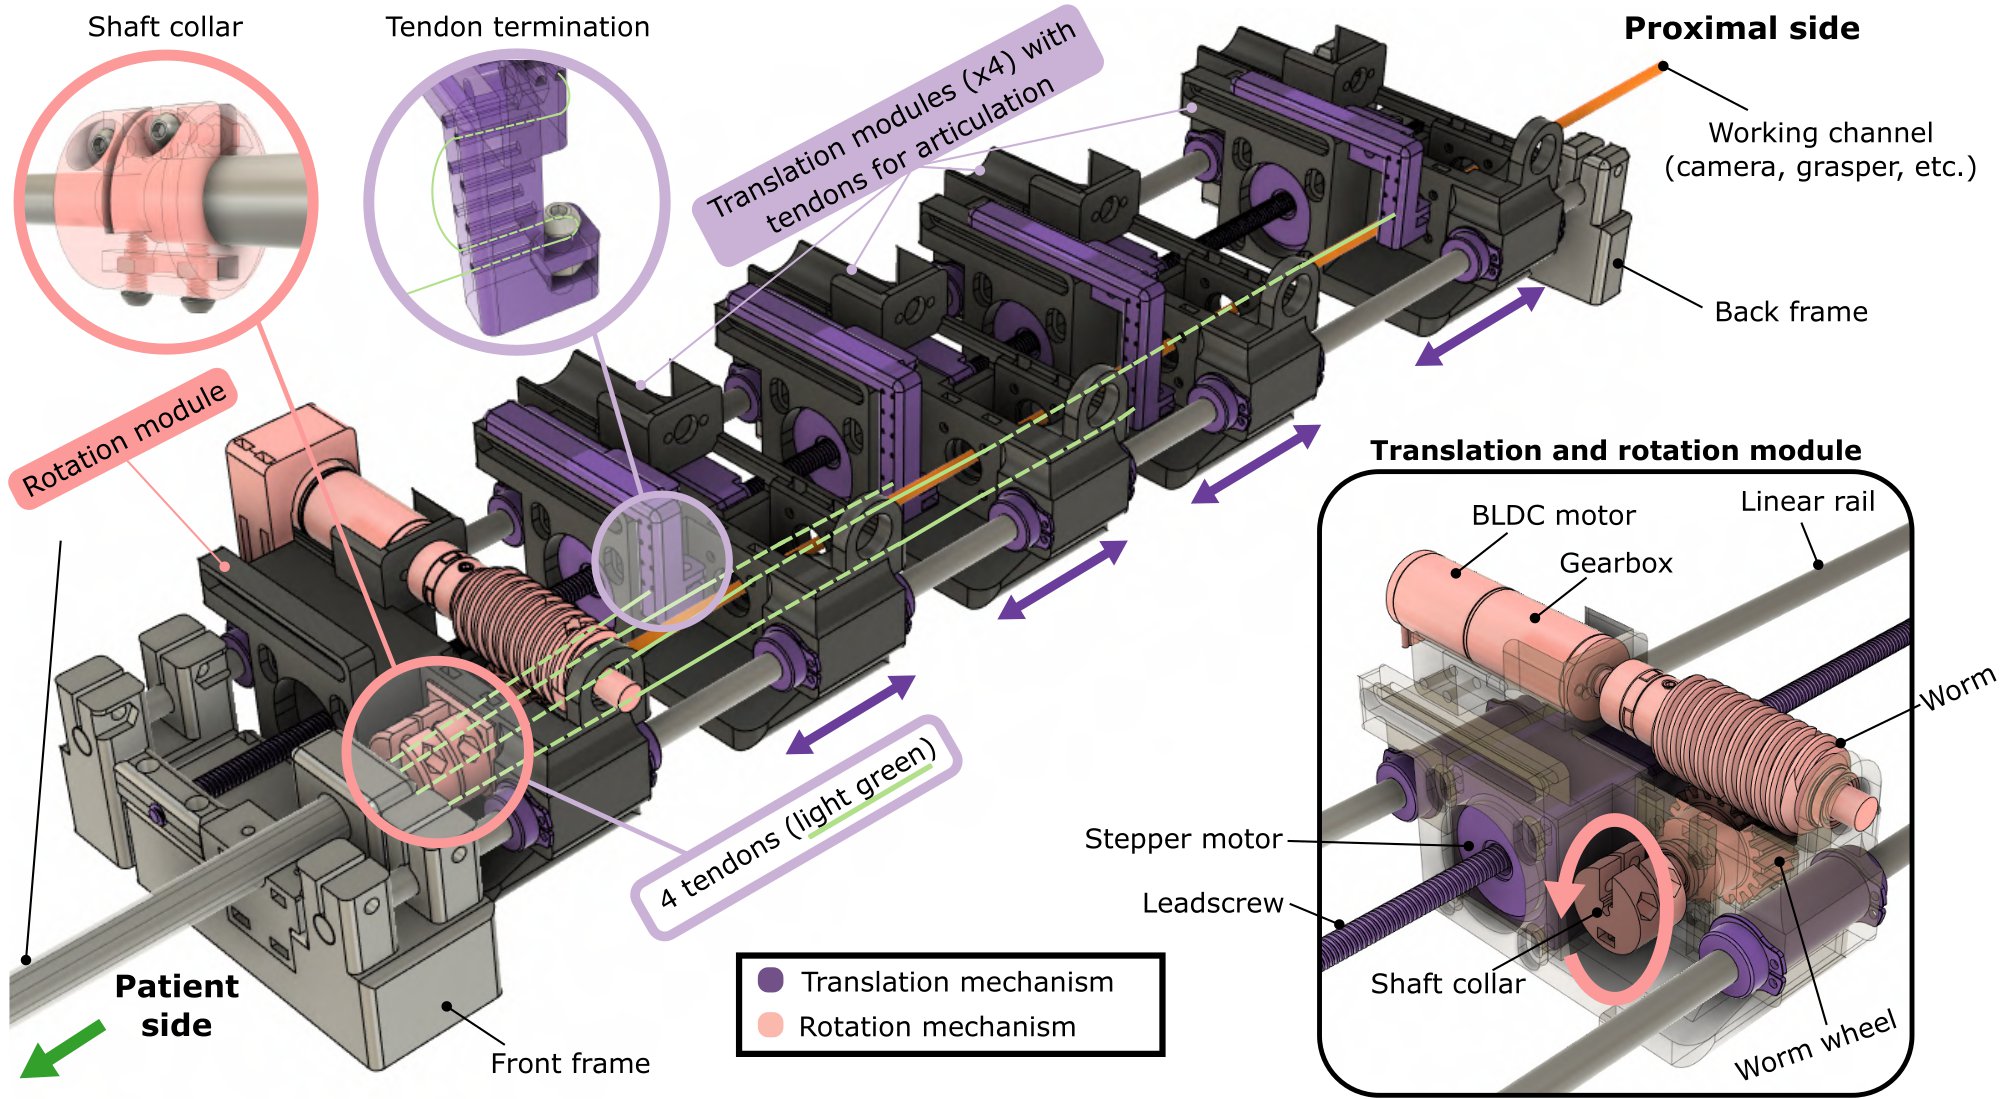
Annotated CAD render of the actuation assembly: a rotation module and four translation modules on linear rails, with tendons routed to each module and a central working channel
An example actuation assembly for a TDCR. Modules can be reconfigured to match the robot's design and number of DOFs. A central working channel accommodates cameras, forceps, and other tools.

Extensions

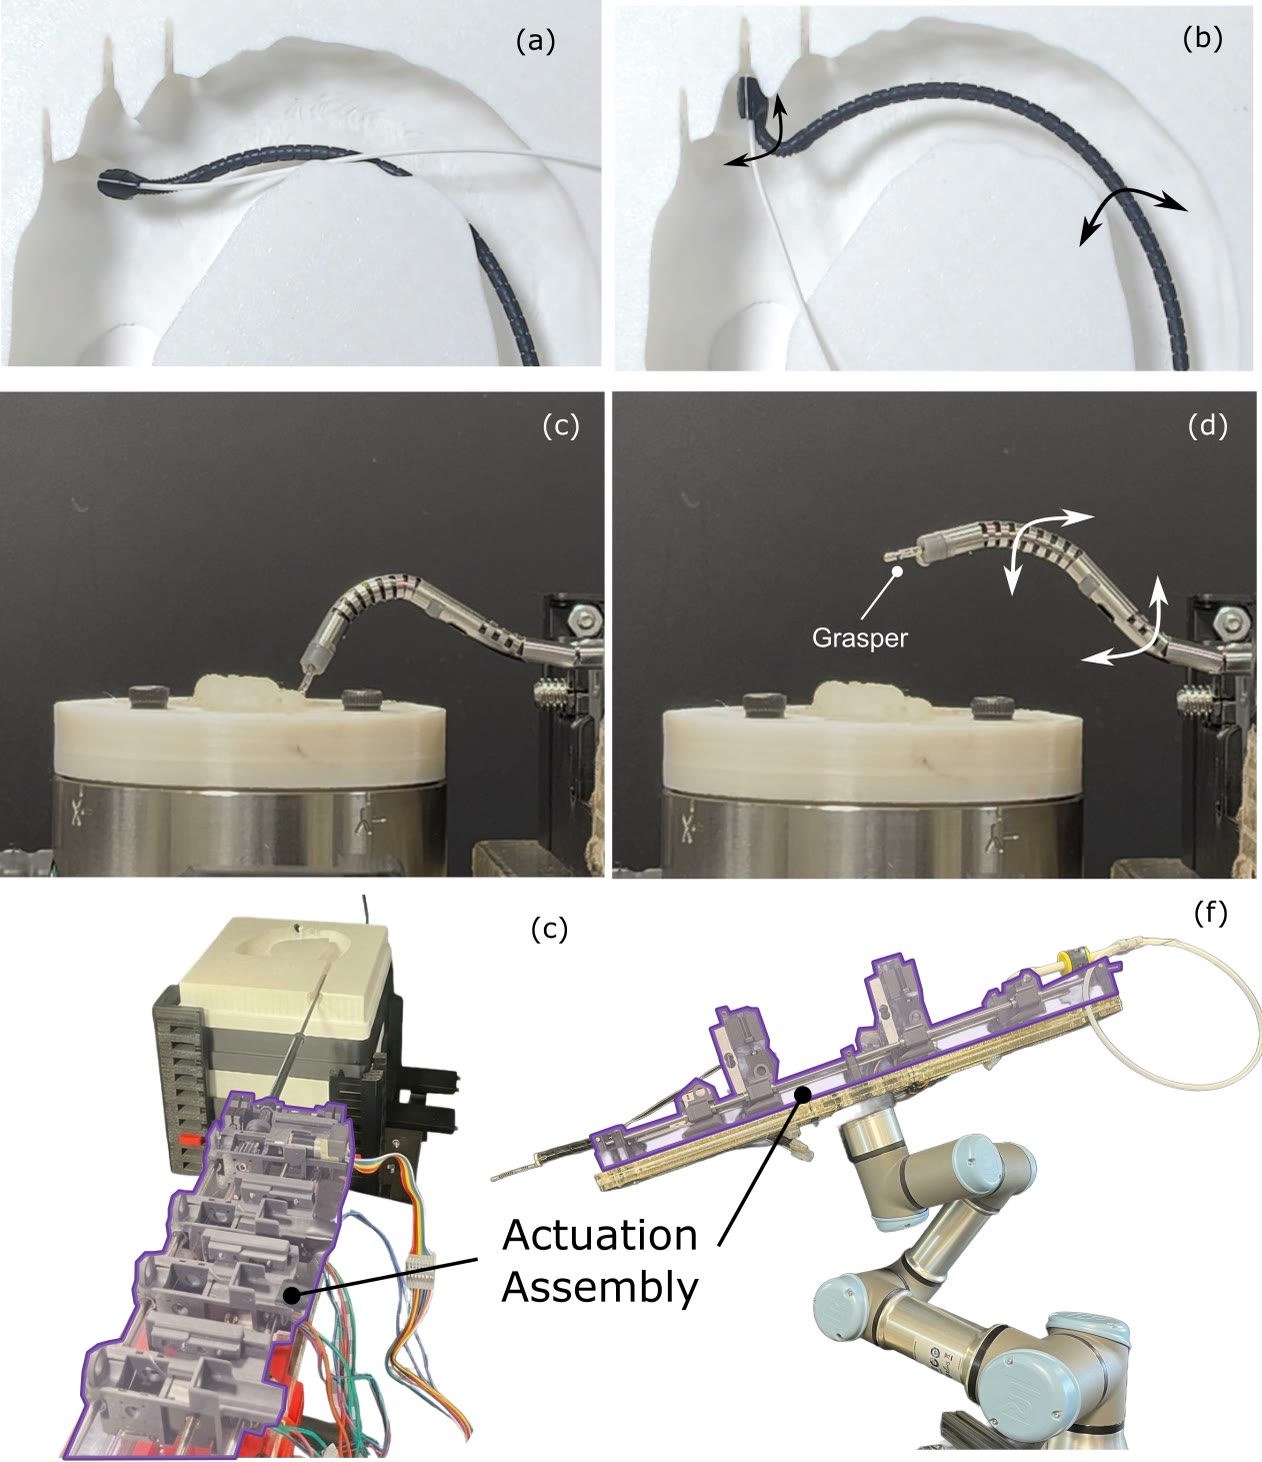
The actuation platform in other applications: a notched TDCR navigating around an aortic arch model, a continuum robotic grasper for submucosal resection, and the actuation assembly mounted on a linear stage and on a UR robotic arm
The proposed actuation platform in different applications and mounting configurations. Top (a–b): autonomous navigation of a notched TDCR around the aortic arch [1]; Middle (c–d): continuum robotic grasper for submucosal resection; Bottom (e–f): mounting configurations on a linear stage and a UR robotic arm.

Papers Using the Platform

  1. Contact-Aware Planning and Control of Continuum Robots in Highly Constrained Environments
    Aedan Mangan, Kehan Long, Ki Myung Brian Lee, Miheer Potdar, Nikolay Atanasov, Tania K. Morimoto
    arXiv preprint arXiv:2604.15638, 2026 · PDF · arXiv

Acknowledgements

The authors would like to thank Noah Jones for his contributions to the electrical integration and initial motor motion control implementation; Sara Sariowan for her contributions to the dVRK attachment design; and Jui-Te Lin for his initial guidance on the instrument actuation design.

BibTeX

@article{xu2026unified,
  title   = {Design and Characterization of a Unified Continuum Robot Actuation Platform},
  author  = {Xu, Yunti and Mangan, Aedan and Potdar, Miheer and Lu, Alex and Morimoto, Tania K.},
  journal = {arXiv preprint arXiv:2610.19798},
  year    = {2026}
}